Research
2026
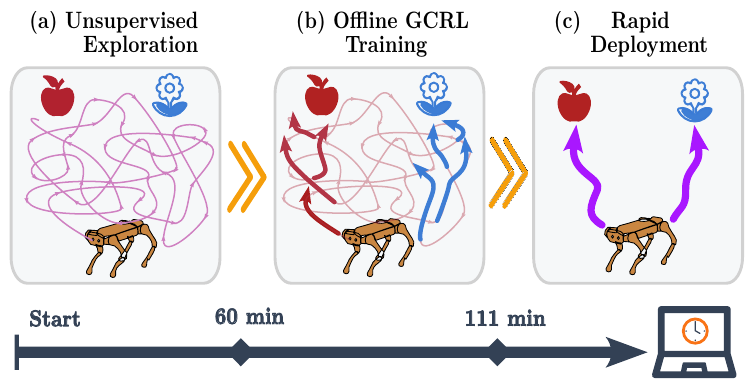
120 Minutes and a Laptop: Minimalist Image-goal Navigation via Unsupervised Exploration and Offline RL
arXiv preprint
·
27 Mar 2026
·
https://arxiv.org/abs/2603.26441
AAAI 2026 · Oral · Top 5%
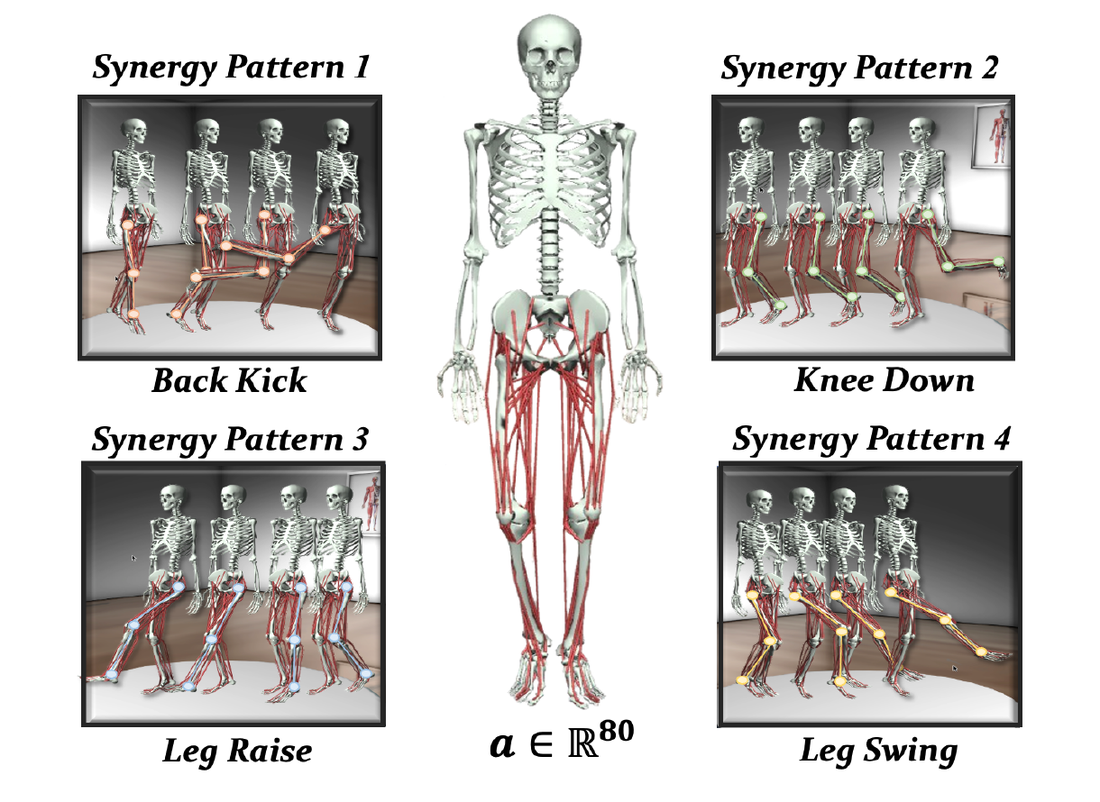
Explore to Learn: Latent Exploration Through Disentangled Synergy Patterns for Reinforcement Learning in Overactuated Control
Proceedings of the AAAI Conference on Artificial Intelligence
·
14 Mar 2026
·
doi:10.1609/aaai.v40i31.39876
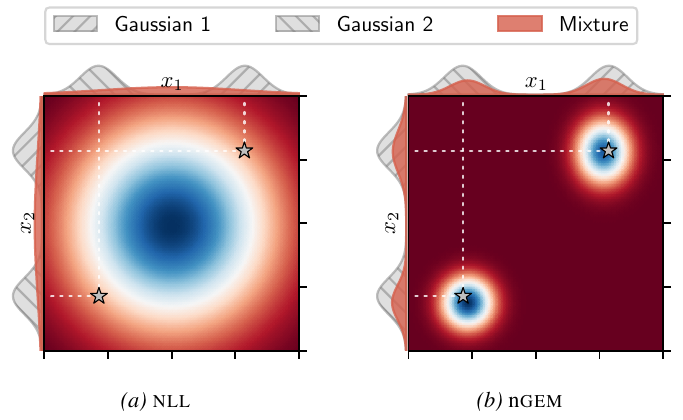
Learning Mixture Density via Natural Gradient Expectation Maximization
arXiv preprint
·
11 Feb 2026
·
https://arxiv.org/abs/2602.10602
ICML 2026 · Spotlight · Top 2.2%
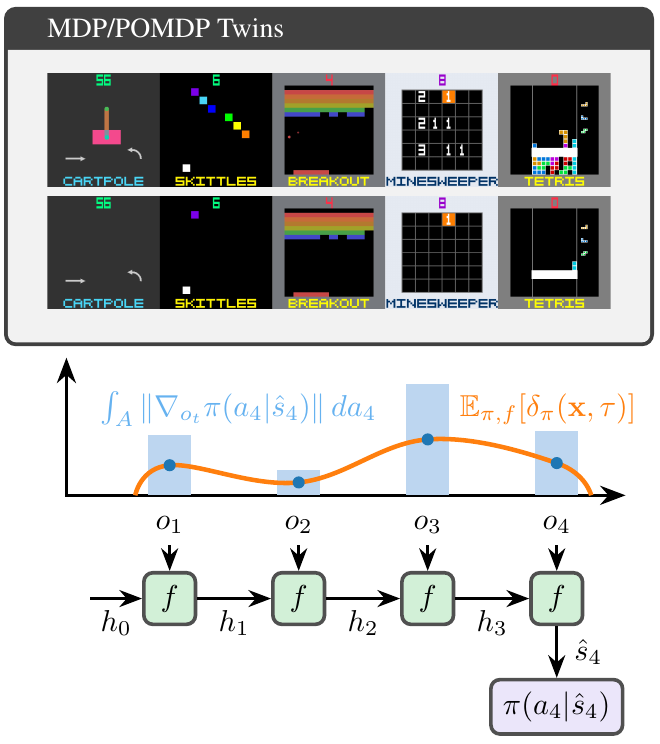
Investigating Memory in Model-Free RL with POPGym Arcade
International Conference on Machine Learning (ICML 2026)
·
https://arxiv.org/abs/2503.01450
2025
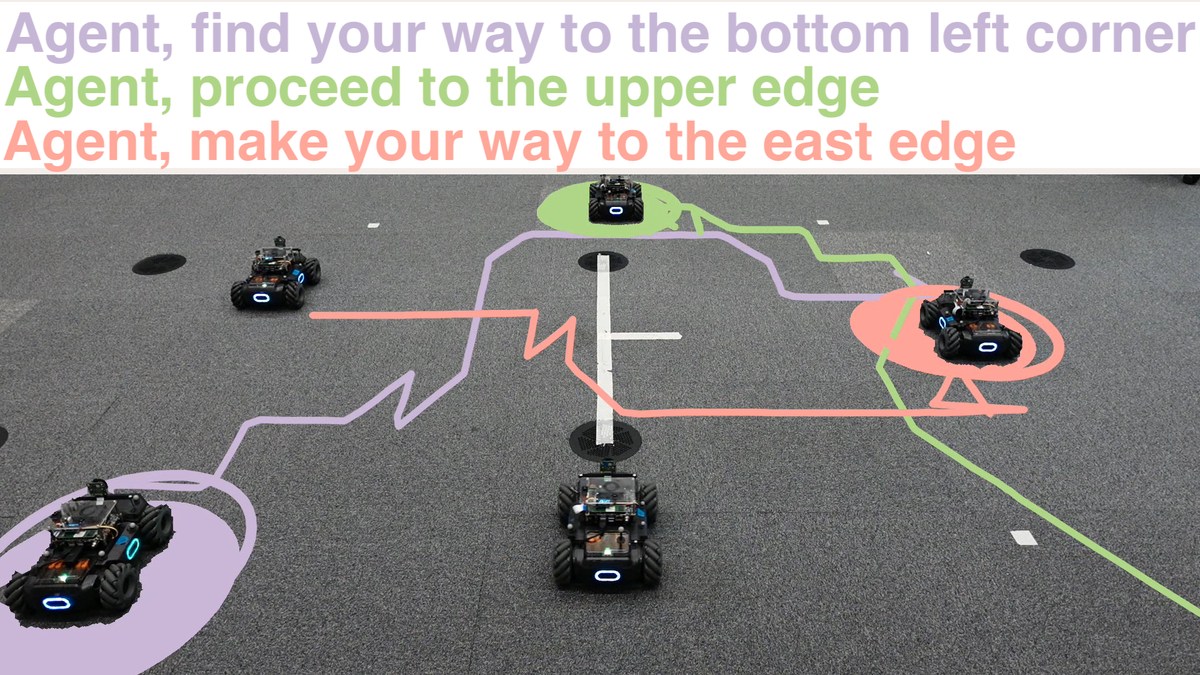
Language-Conditioned Offline RL for Multi-Robot Navigation
2025 IEEE International Conference on Robotics and Automation (ICRA)
·
19 May 2025
·
doi:10.1109/ICRA55743.2025.11127288
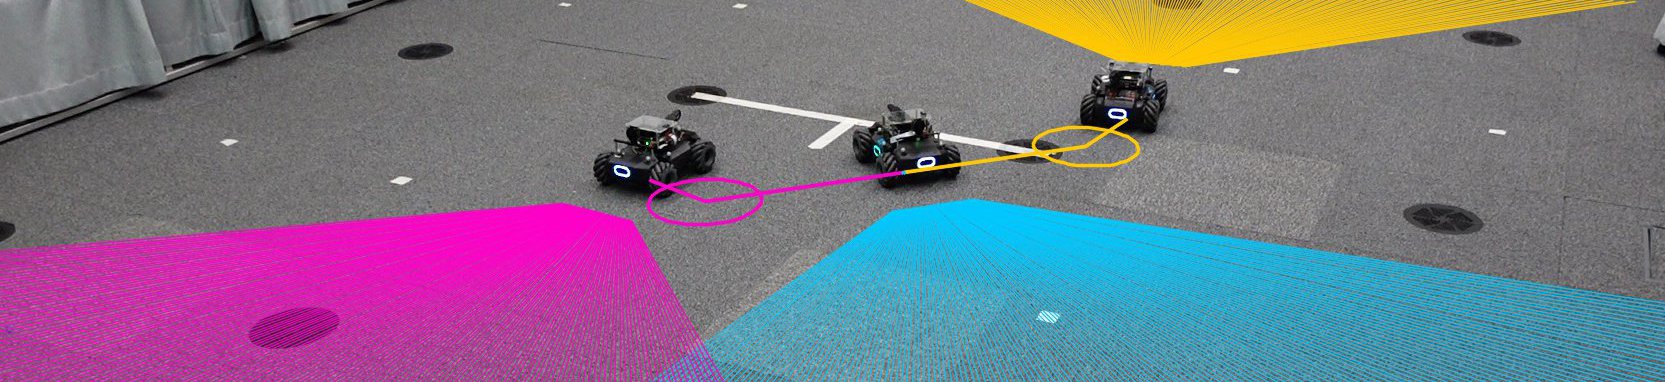
CoViS-Net: A Cooperative Visual Spatial Foundation Model for Multi-Robot Applications
Conference on Robot Learning (CoRL 2024), PMLR 270
·
12 Jan 2025
·
https://proceedings.mlr.press/v270/blumenkamp25a.html
2024
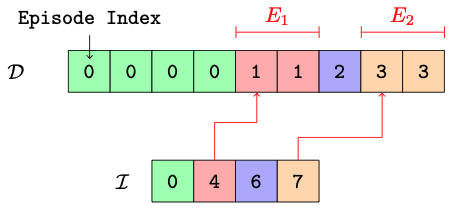
Recurrent Reinforcement Learning with Memoroids
Advances in Neural Information Processing Systems
·
26 Sep 2024
·
https://openreview.net/forum?id=nA4Q983a1v
2023
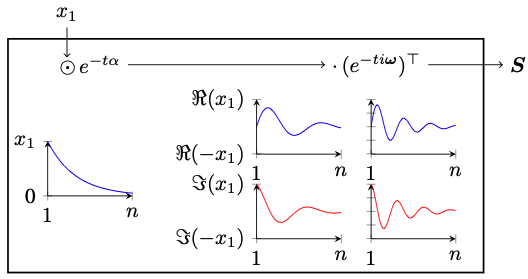
Reinforcement Learning with Fast and Forgetful Memory
Advances in Neural Information Processing Systems
·
22 Sep 2023
·
https://openreview.net/forum?id=KTfAtro6vP
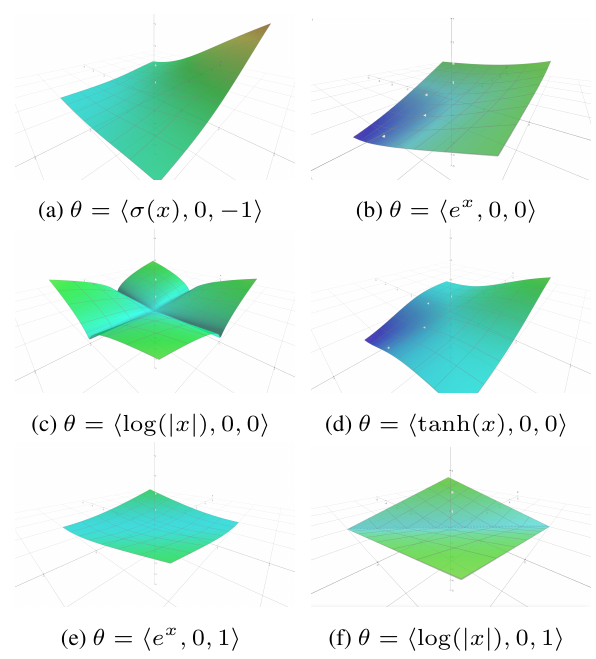
Generalised f-Mean Aggregation for Graph Neural Networks
Advances in Neural Information Processing Systems
·
22 Sep 2023
·
https://openreview.net/forum?id=JMrIeKjTAe
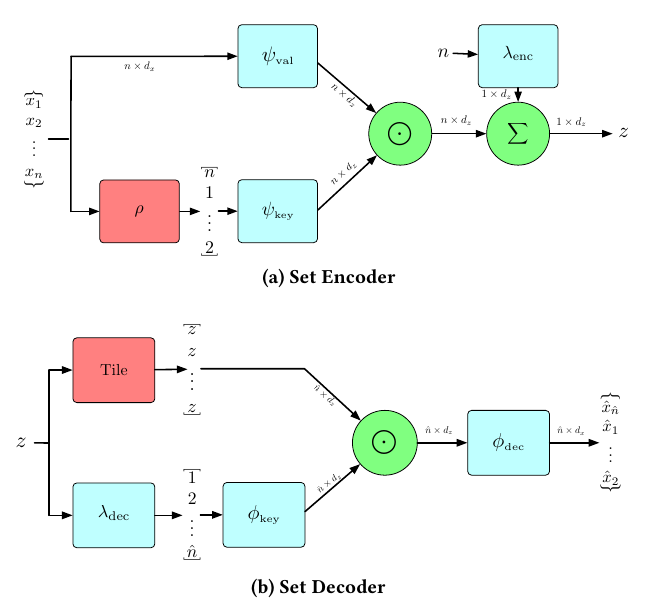
Permutation-Invariant Set Autoencoders with Fixed-Size Embeddings for Multi-Agent Learning
International Conference on Autonomous Agents and Multiagent Systems
·
30 May 2023
·
https://arxiv.org/abs/2302.12826
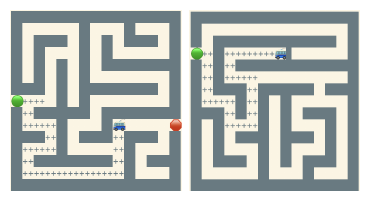
POPGym: Benchmarking Partially Observable Reinforcement Learning
The Eleventh International Conference on Learning Representations
·
01 Feb 2023
·
https://openreview.net/forum?id=chDrutUTs0K
2022
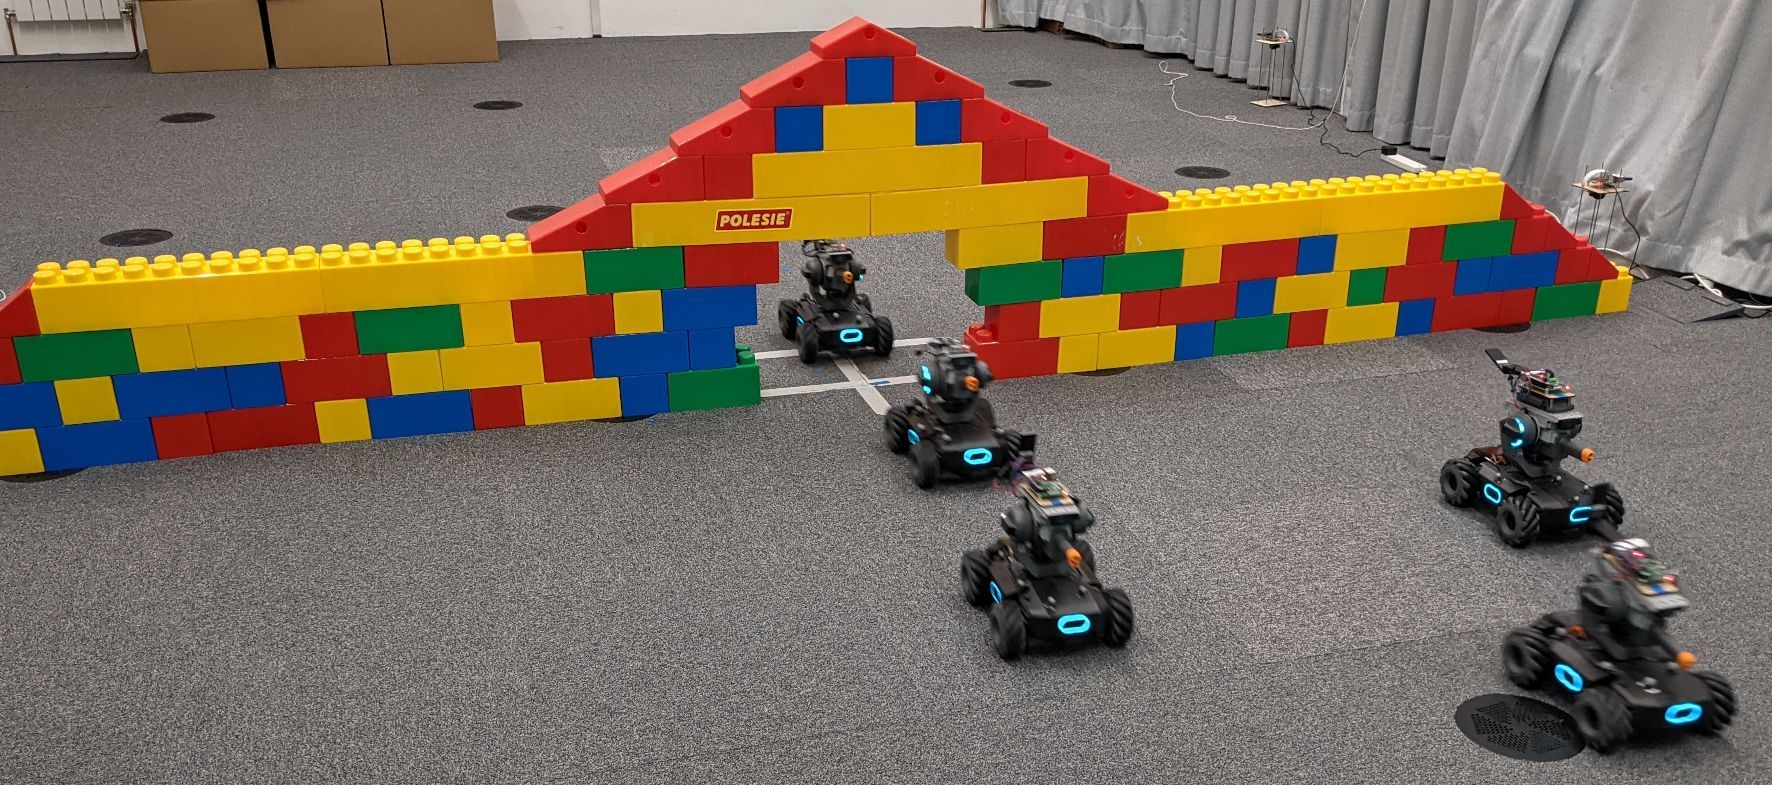
A Framework for Real-World Multi-Robot Systems Running Decentralized GNN-Based Policies
2022 International Conference on Robotics and Automation (ICRA)
·
23 May 2022
·
doi:10.1109/ICRA46639.2022.9811744
2021
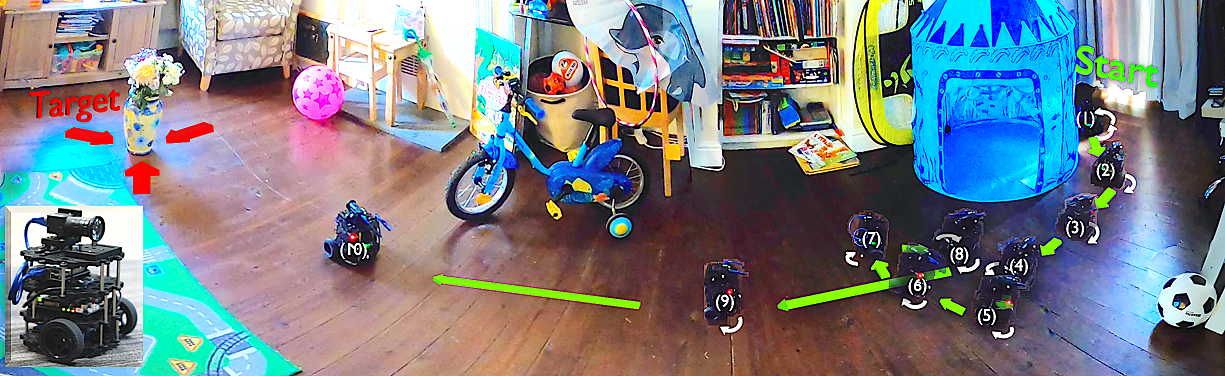
Embodied Visual Navigation With Automatic Curriculum Learning in Real Environments
IEEE Robotics and Automation Letters
·
01 Apr 2021
·
doi:10.1109/LRA.2020.3048662
2020
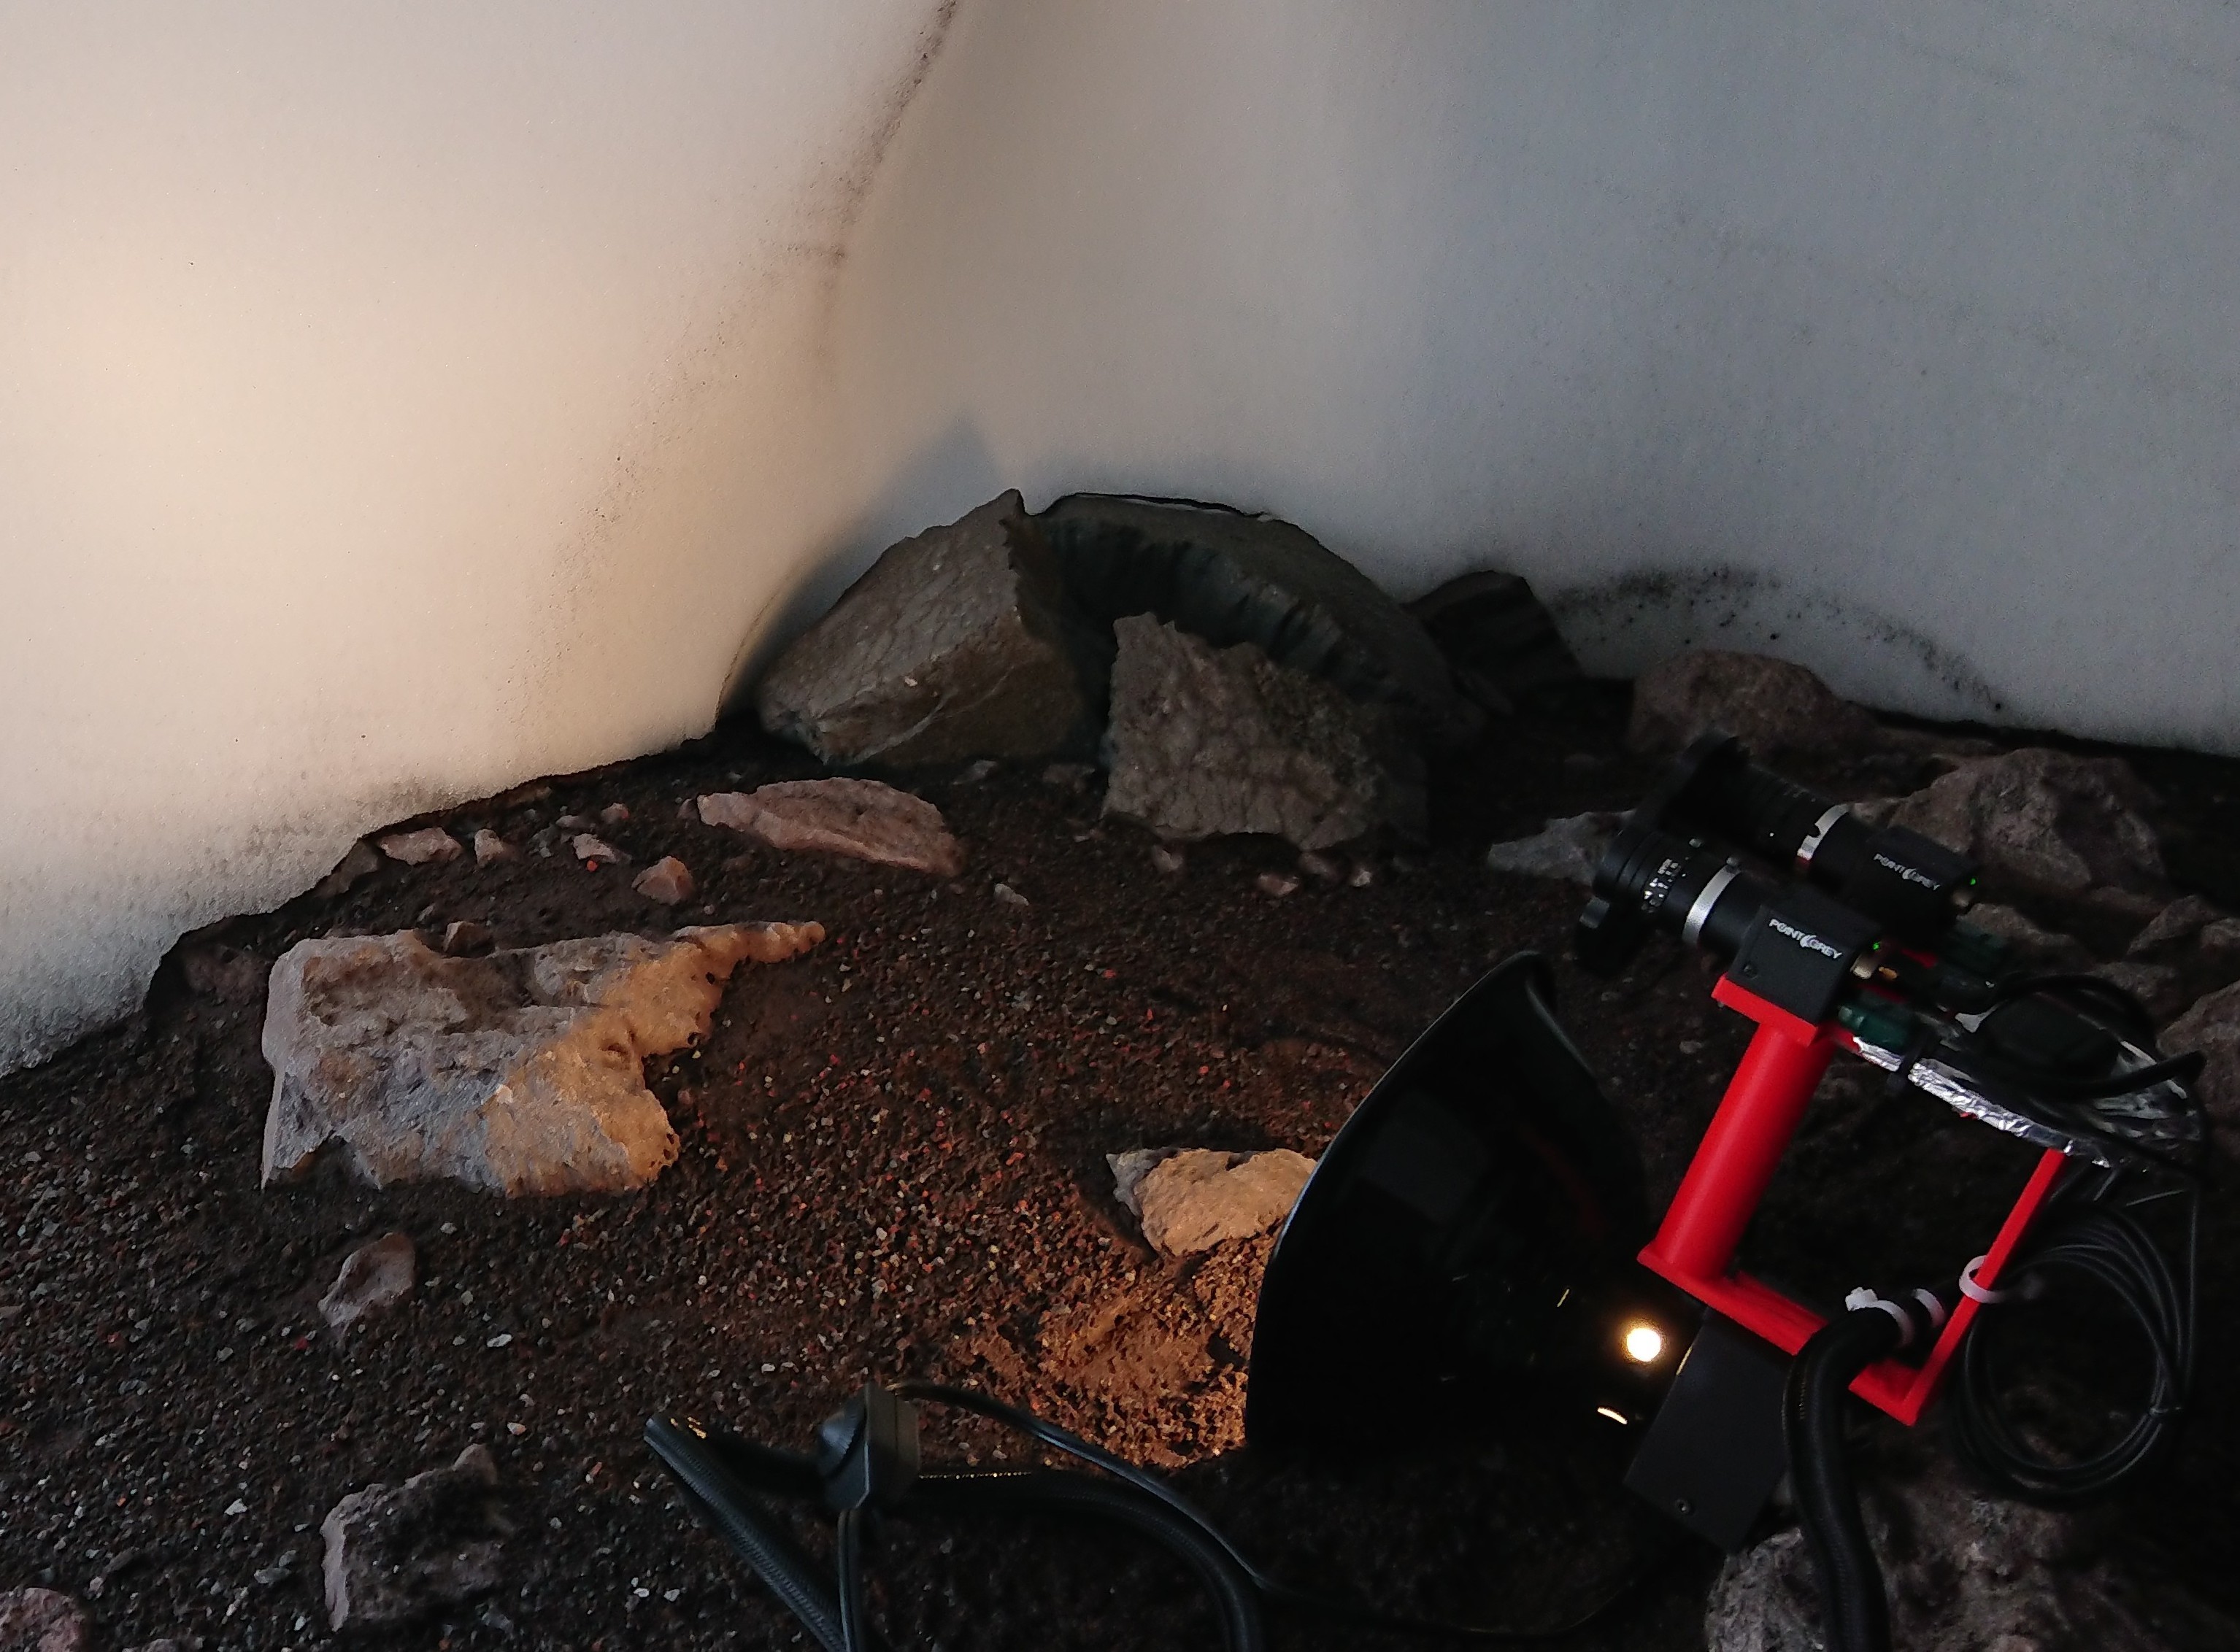
Improving Visual Feature Extraction in Glacial Environments
IEEE Robotics and Automation Letters
·
01 Apr 2020
·
doi:10.1109/LRA.2019.2959490
2019
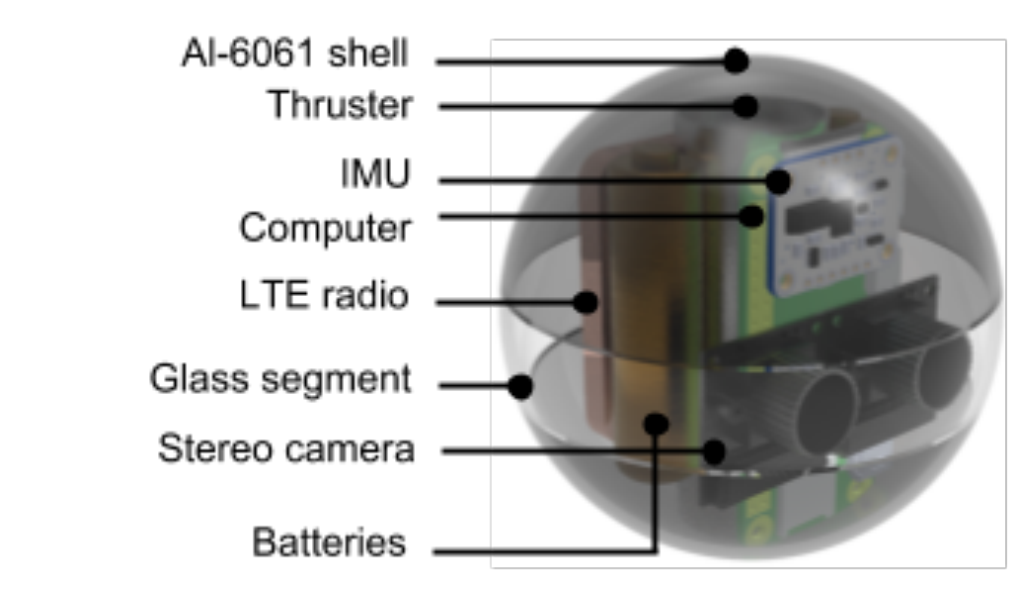
A Spring Propelled Extreme Environment Robot for Off-World Cave Exploration
2019 IEEE Aerospace Conference
·
01 Mar 2019
·
doi:10.1109/AERO.2019.8741609